
First-semester engineering project · 2024
Robot competition
Speed. Sensing. Trajectory.
Working in a pair, I designed two circuit boards and programmed an autonomous robot for a speed competition.
Completed during my first year of Electrical Engineering, this project involved the entire embedded-system chain: analysis, electronics, manufacturing, programming and track testing.
Technical context
Balance speed and detection
Every team received the same chassis. Together with Dimitri Léguillon, we had to stand out through our boards, driving strategy and software reliability when facing walls, turns and an opposing robot.
Take the lead
We chose to accelerate as hard as possible over the first metre to pass the opposing robot before it could obstruct our trajectory.
Stay centred
Our program continuously compares the distances to the left and right walls, then balances motor speed to remain in the centre of the track.
Interactive track model
Timer0.00 s
What I developed
Build the sense, decide, correct loop
I contributed to sensor acquisition, wall-proximity interpretation and independent motor control. This loop directly connected our electronic choices to the robot’s behaviour.
Sensors
Side distances, floor and limit switches
Arduino Uno
C++ decision and correction
H-bridge
Motor direction and power
Trajectory
Move, turn and avoid
Electronic design
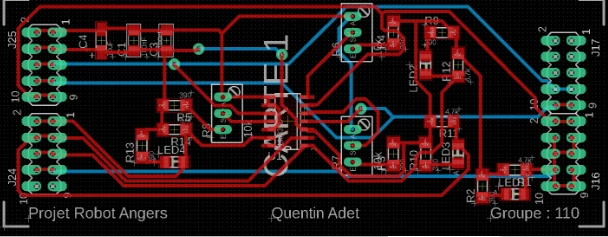
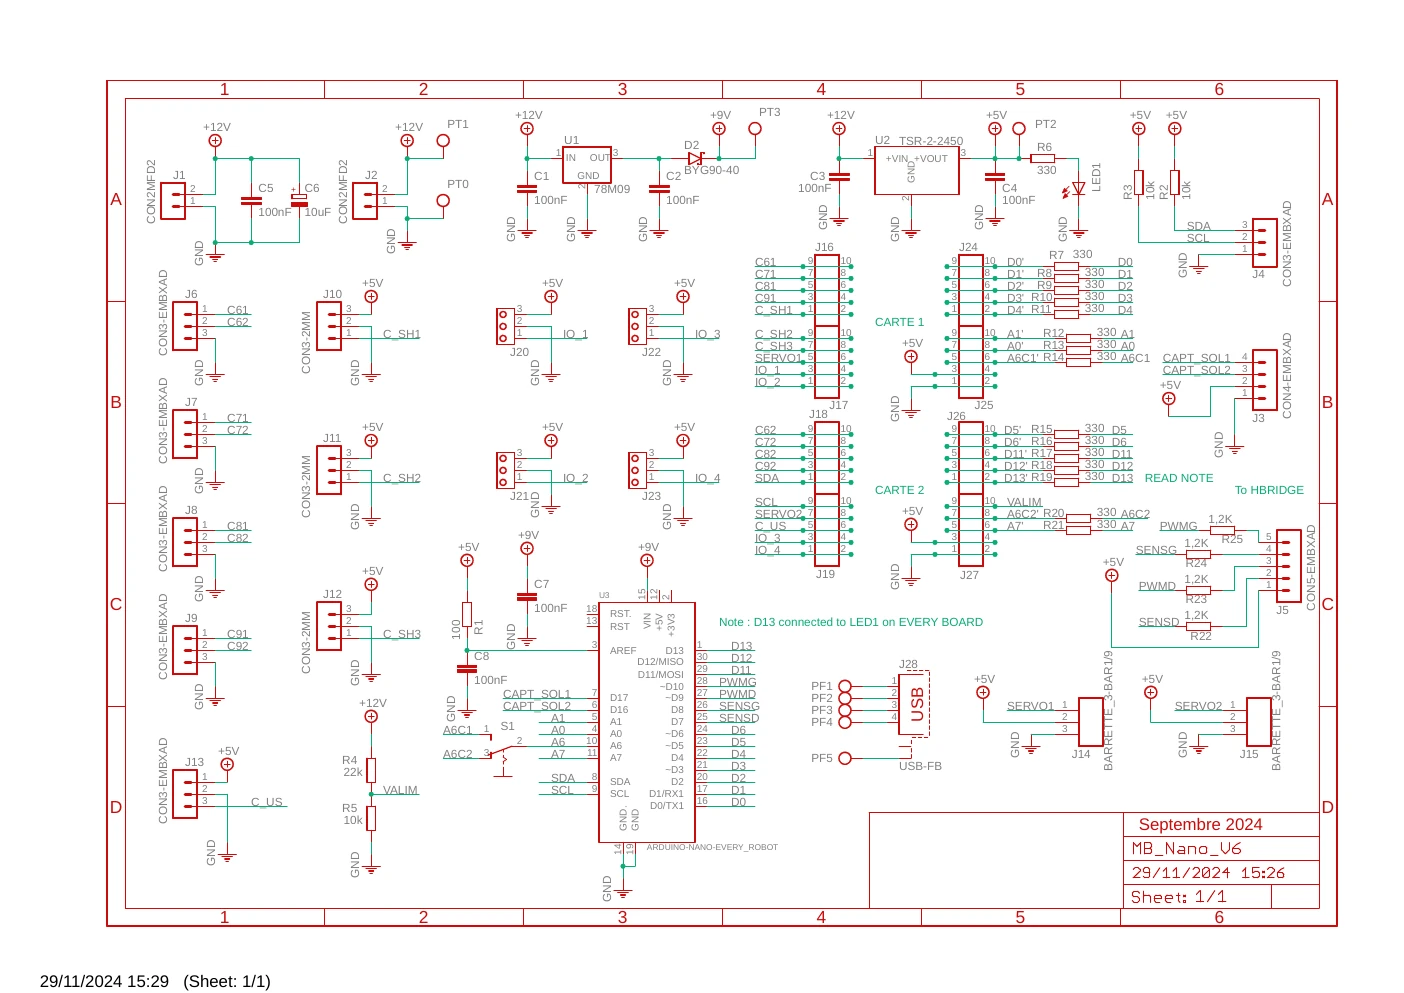
Two boards to instrument the robot
With my teammate, I contributed to sizing, schematics, routing, assembly and testing of both boards before integrating them into the robot.
Board 1 · Sensors
Three LM339 comparators convert Sharp sensor measurements into usable states. Potentiometers set thresholds and LEDs make diagnostics easier.
Board 2 · Interface
An HCF4511 drives the seven-segment display to show program state. A voltmeter monitors the battery and a jack input provides synchronisation.
My approach
Move from analysis to testing
Debug log
Two faults, two corrections
Testing taught me not to look for faults only in software: I compared schematics, PCB connections and measured signals to isolate each issue.
A0 / A1 swapped
The analogue readings did not match the expected sensors. Oscilloscope measurements confirmed the swap, which we corrected in software.
D13 unavailable
The pin selected for the jack was connected to the Arduino Uno internal LED. We moved the signal to a free input and modified the PCB.
Result
Quarter-finalist
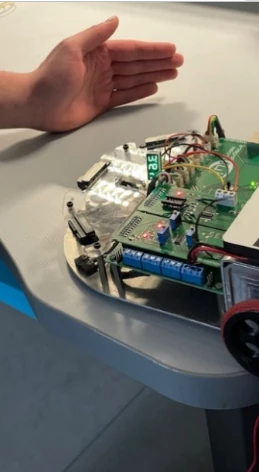
Our robot completed the course and reached the quarter-finals. Beyond the ranking, I validated my ability to design, manufacture and debug a complete electronic system under a real performance constraint.
What we would improve
The final control mainly used digital states from the Sharp sensors, so the response remained identical regardless of wall distance. In a new version, we would use analogue readings to progressively adjust each motor, improve smoothness and retain more speed through turns.
Collaboration across the full chain
Together with Dimitri Léguillon, I worked on analysis, electronics, manufacturing, testing and software.
Documentation